Research

Pillar I

Biorobotics

Novel mechanisms and control methods that exploit the natural dynamics of the robot.

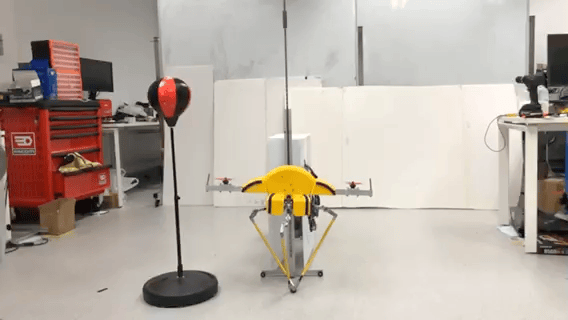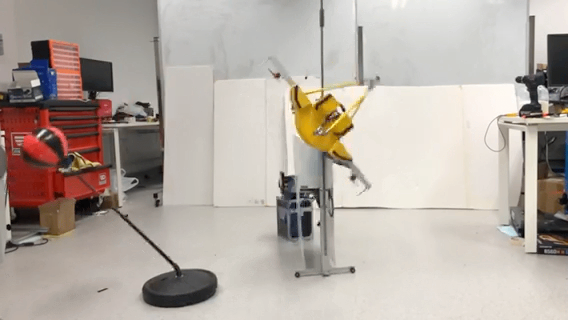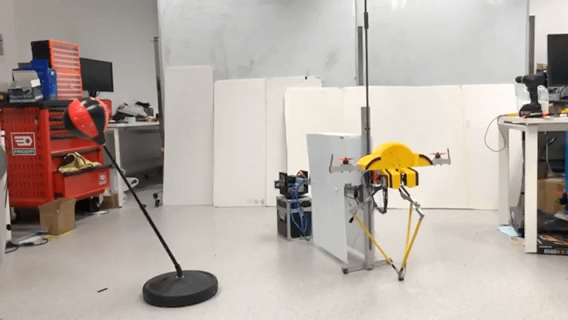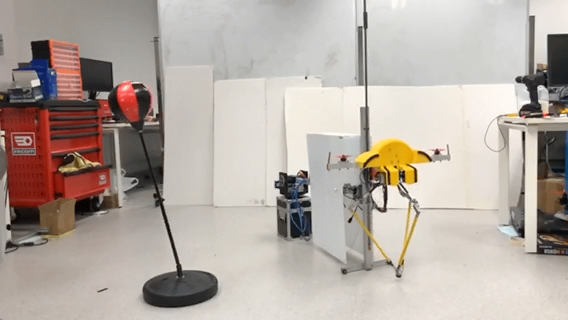
A bipedal robot with an inertial tail kicking a punching bag

1Bioinspired Agile Locomotion

Key directions

  • Aerial reorientation inspired by kangaroo rats
  • Morphable tails for self-righting and safe landing
  • Hopping robots
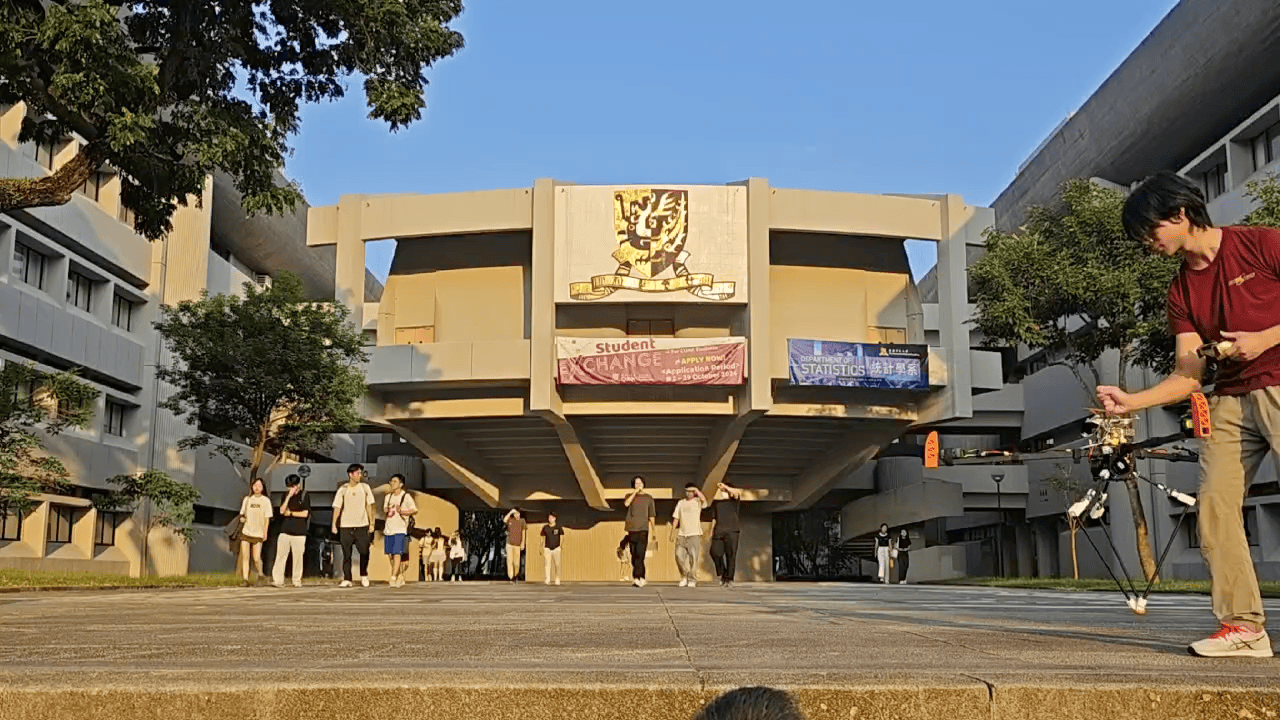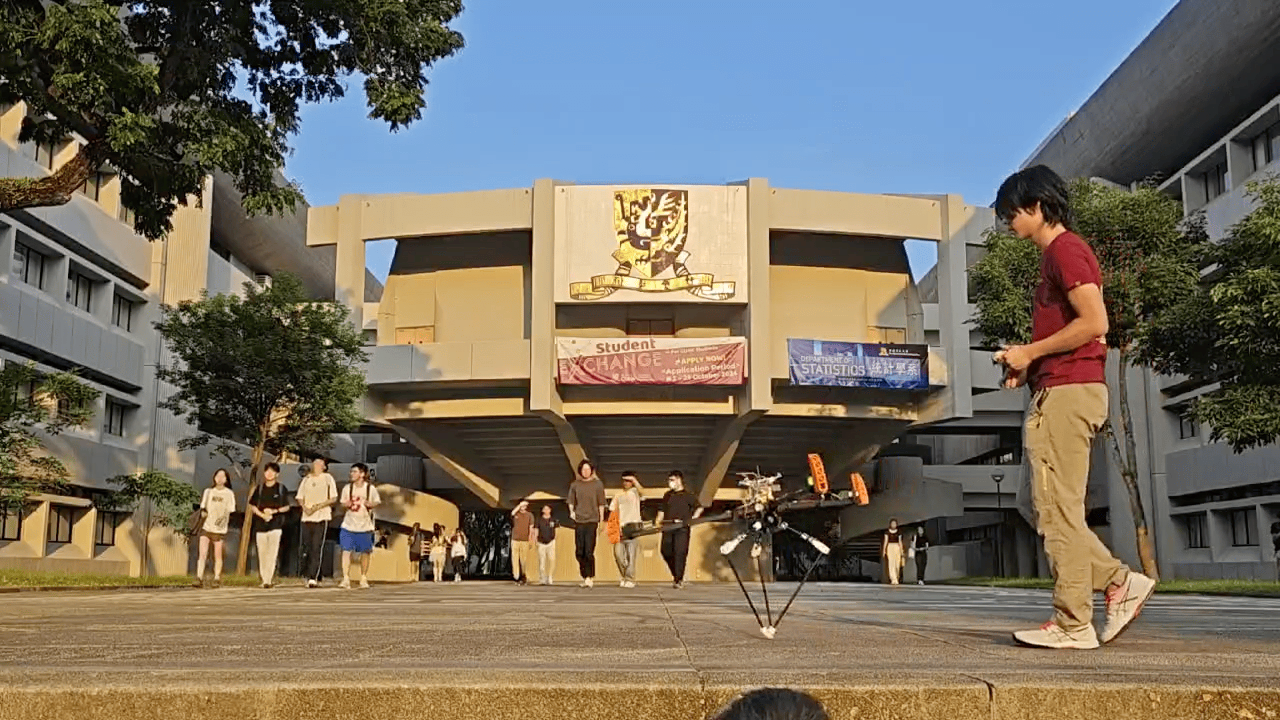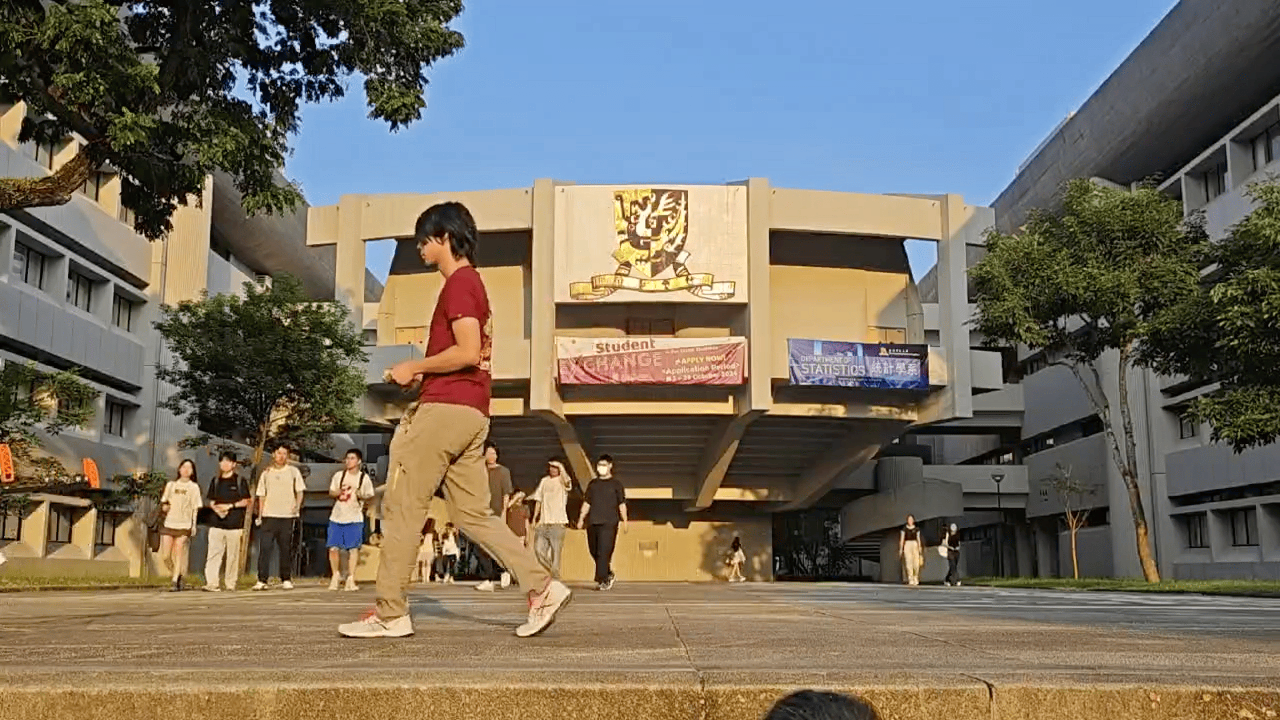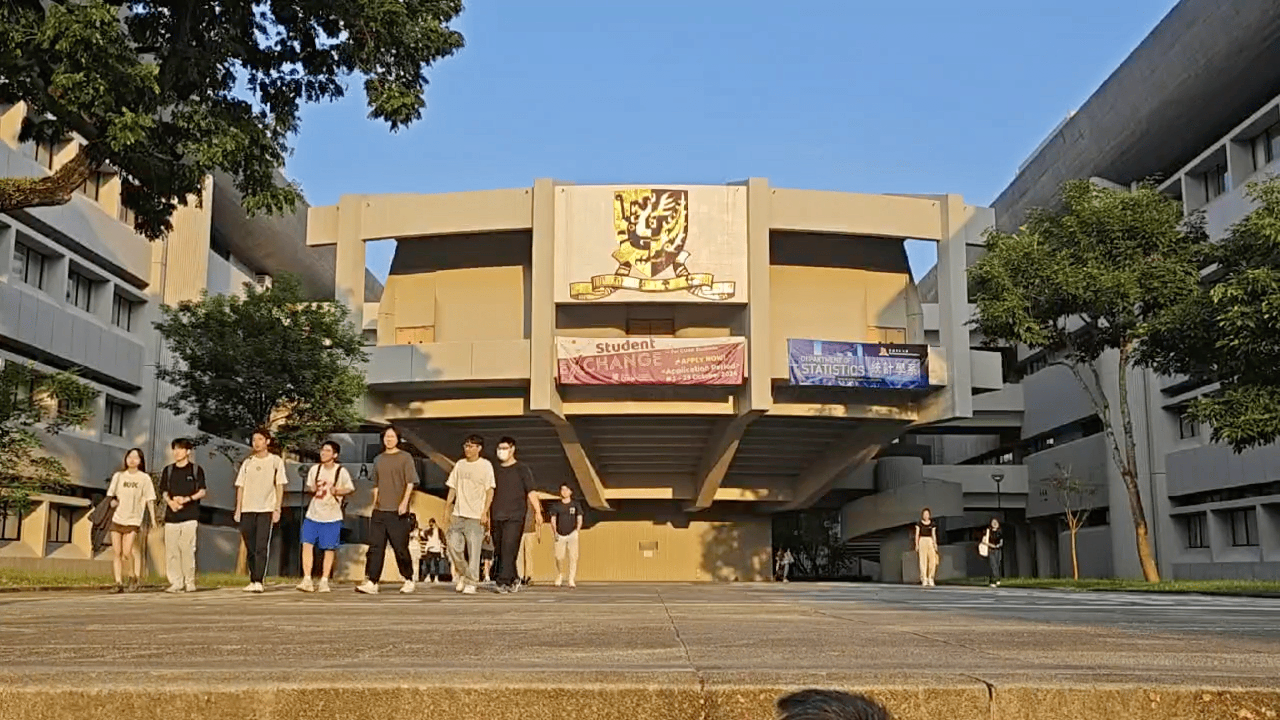
The OMEGA hopping robot hopping outdoors on the CUHK campus

2Control of Underactuated Systems

Key directions

  • Null-space avoidance for underactuated robots
  • QP control of reorientation and contact forces
  • Nonholonomic vehicles and rigid-body attitude control
Pillar II

Medical Technology

Built with surgeons and industry, from the lab to real clinical settings.

Teleoperated surgical instrument constrained by translational and rotational virtual fixtures

3Dexterous Surgical Instruments

Key directions

  • Virtual fixture for safe instrument control
  • Steerable drills for spine and bone surgery
  • Bendable instruments for confined surgical spaces
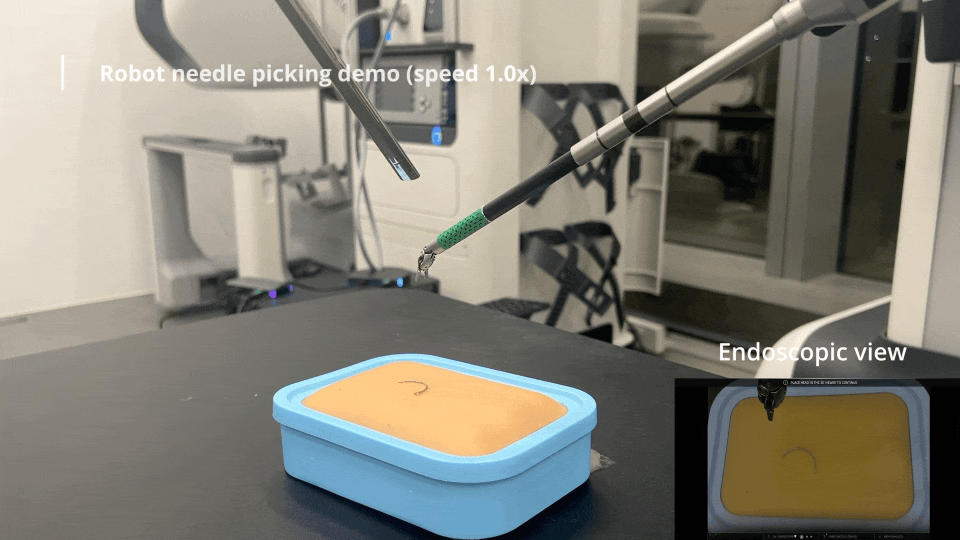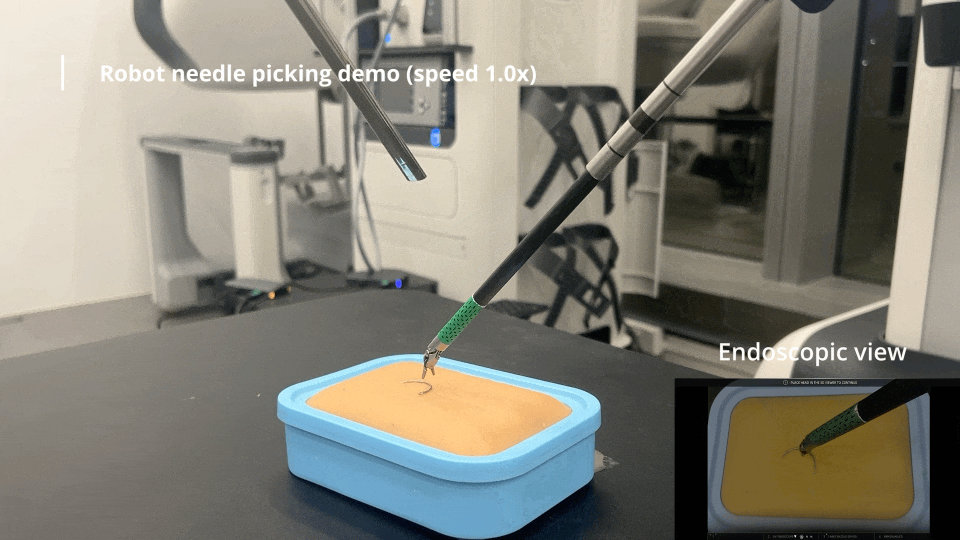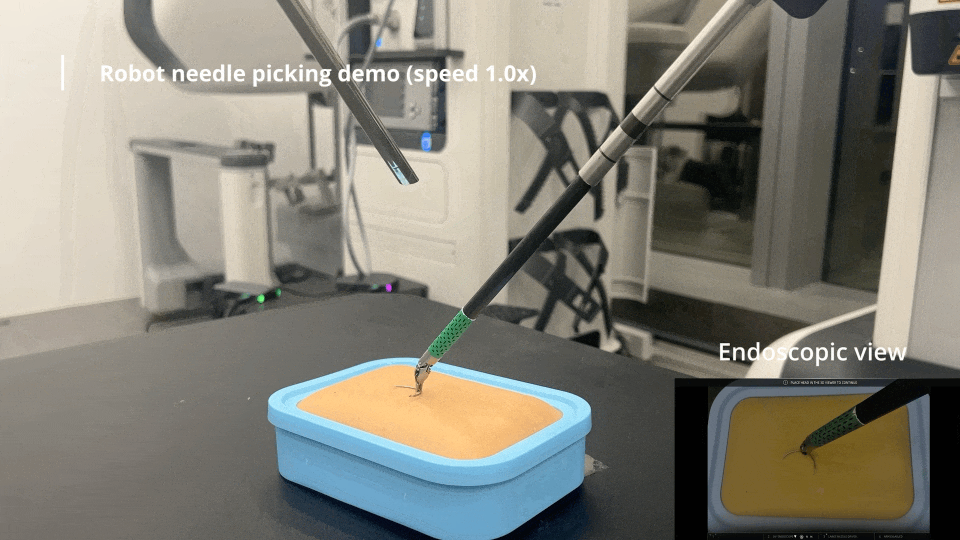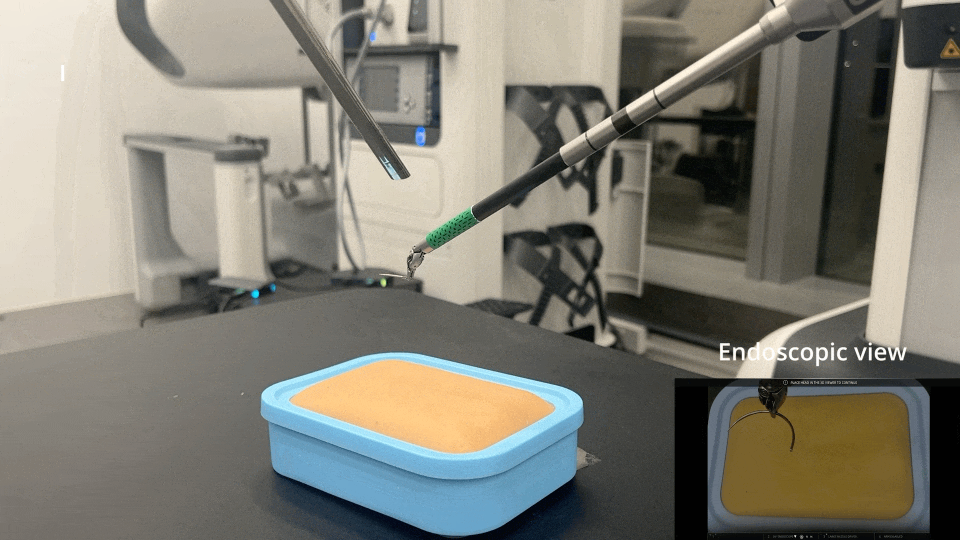
A Cornerstone Robotics surgical robot autonomously picking up a surgical needle

4Surgical Autonomy

Key directions

  • Surgical robot research kit
  • Soft tissue manipulation
  • Long-horizon surgical procedure learning